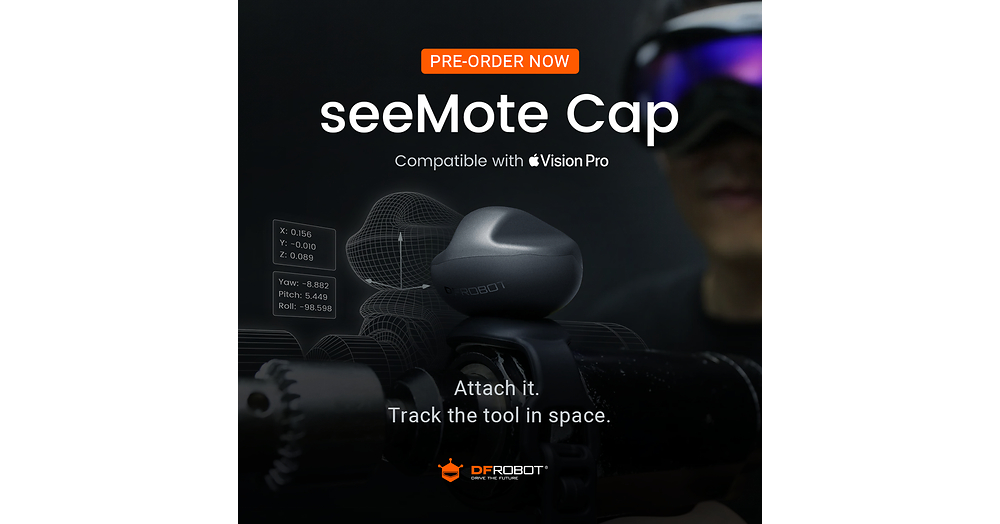
The module functions by mapping the physical position, orientation, and motion of a tool directly into visionOS application logic. This approach preserves the tactile experience of using familiar instruments, an essential factor for high-precision sectors like medical simulation and industrial assembly training. A demonstration of the technology recently showcased the cap attached to an orthopedic drill, proving how physical operating sequences can be translated into digital skill assessment tools.
To facilitate integration, DFRobot has released a suite of developer resources, including Swift SDK support, USDZ models, and .referenceaccessory files. The hardware is designed for versatility, featuring a lightweight frame that attaches to a variety of surfaces. Preorders are currently open, with the first units scheduled to ship in late September 2026.
Comments (0)
No comments yet. Be the first!